Mechatronics engineer · Annecy, France

Seeking a PhD position in robotics, control and AI

Teaching machines to observe what they cannot measure.

I am Samsaam, a mechatronics engineer working at the intersection of control theory, robotics and machine learning. My recent work is a physics-informed neural network observer that reconstructs the hidden states of a quadrotor from partial measurements.

  • Annecy, France
  • MSc Advanced Mechatronics
  • English C1 · French A2
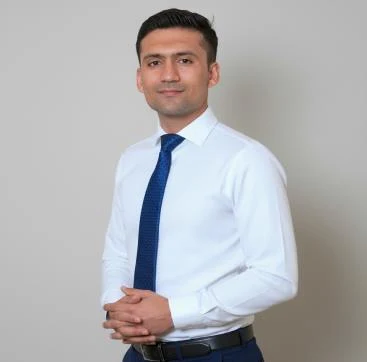
Portrait of Samsaam Ali Baig
RMSE 0.056 on hidden states
12 state quadrotor observer
12state UAV observer built in PyTorch
±20%model error the observer stays robust to
100+schools in 10 countries in a carbon monitoring programme
360ECTS across mechanical engineering and mechatronics

01 · About

Control, estimation and learning for autonomous systems.

I hold a Master's in Advanced Mechatronics from Polytech Annecy (Université Savoie Mont Blanc) and a Bachelor's in Mechanical Engineering from UET Peshawar. My focus is nonlinear observer design, physics-informed neural networks and safety critical control for autonomous systems.

I enjoy the full loop: deriving the model, simulating it in MATLAB/Simulink or Gazebo, writing the ROS and embedded code, and validating it against real data from sensors such as force platforms, IMUs, Lidar and EMG.

Before mechatronics I worked on 3D modelling and multiphysics simulation at NUST, and on energy monitoring and sustainability with the Aga Khan Development Network in Pakistan, London and Geneva. I am now looking for a PhD where control, robotics and AI meet.

02 · Research

A physics-informed neural network observer for a twelve state quadrotor under partial measurement

Master thesis · Research internship

DRIVE-SIC Laboratory, ISAT, Université Bourgogne Europe · May to September 2026 · Supervised by Dr. Ahmed Chaibet

A quadrotor's controller needs its full state, but onboard sensors usually measure only part of it. I designed and trained a PINN observer in PyTorch that reconstructs the six hidden velocity states from partial pose measurements, extending the PINN-Obs method to a full twelve state, controller driven system.

  • Generalises to unseen trajectories across circle, figure eight and spiral paths
  • Robust to sensor noise and to ±20% model parameter error
  • Includes an original negative result on the method's adaptive learned gain
  • First author of a journal paper (in preparation) with reproducible code and datasets

Observer RMSE on an unseen spiral flight

Measured states (6)
0.044
Hidden states (6)
0.056
All states (12)
0.050
PyTorchPINNNonlinear observersUAV dynamicsState estimation
Code and datasets on GitHub
True versus estimated 3D trajectory on an unseen flight.
Simulation pipeline, from reference path to observer output.
All twelve states on an unseen test flight.

03 · Projects

From biomechanics to robots and AI tooling.

M2 collective research · Polytech Annecy · 2025

Biomechanical and neuromuscular analysis of the ankle in postural control

A real time synchronised sensing system combining a Kistler force platform for ground reaction forces, ArUco marker tracking for joint angles and EMG sensors for muscle activation, with signal processing (FFT, PSD) and an inverted pendulum model of the ankle.

KistlerEMGArUcoMATLAB

M2 research · Polytech Annecy · 18+ model iterations

Effect of body weight on the ankle mechanism

Derived the governing equation, built a Simulink signal model with parameter sweeps and a Simscape Multibody model with spring damper, then validated it at 0.39 Hz against Kistler platform data. Swept body mass from 52 to 102 kg: stability margin fell from 116% to 10%.

I·θ̈ + B·θ̇ + (S − mgh)·θ = τ

Simscape MultibodySimulinkProsthetics

M2 individual project · Dec 2025

MCP server connecting an LLM to MATLAB and SolidWorks

A two way architecture based on the Model Context Protocol that lets Claude drive MATLAB/Simulink simulations and build parts in SolidWorks from natural language: sketches, extrusions, fillets and simulation runs, with feedback returned to the model.

MCPPythonMATLAB APISolidWorks API
View on GitHub

Team project (8 people) · Polytech Annecy · 2025

Eurobot challenge: autonomous robot in ROS 2 and Gazebo

Autonomous robot for hazelnut crate collection. I did the CAD modelling and assembly, and worked on path planning, obstacle avoidance and waypoint navigation with the Navigation2 stack (AMCL, slam_toolbox), validated in Gazebo.

ROS 2 HumbleNav2GazeboSolidWorks

M2 collective project · Smart healthcare IoT

Smart pillbox with automated alerts

An assistive embedded device on an ESP32 with reed switches and FSR sensors, timer driven dispensing, a Flask web server for remote monitoring and WhatsApp alerts to caregivers through CallMeBot on missed doses. Enclosure designed in SolidWorks and 3D printed.

ESP32FlaskIoT3D printing

Aga Khan Schools · Geneva · Jul to Nov 2025

Energy and carbon monitoring across 100+ schools

Defined baseline green metrics and calculation policies for energy and CO₂ emissions, tracked 7 indicators across Africa, Asia and the Middle East, and built a prototype web dashboard with a map view and green, orange or red compliance status per standard.

DataHTML/JSSustainability

Polytech Annecy

Mobile robotics on the Horizon Sunrise X3 Pi

High level control nodes in ROS 1 Noetic, simulated in Gazebo and visualised in RViz. Integrated and calibrated IMU, Lidar and camera for localisation and mapping.

ROS 1 NoeticSLAMRVizSensor fusion

Undergraduate thesis · UET Peshawar

Dynamic modelling of oil emulsion separation

Dynamic modelling and finite element simulation of oil in water and water in oil emulsion behaviour in COMSOL Multiphysics.

COMSOLFEAMultiphase flow
Earlier mechanical engineering work
  • 3D modelling of a jet turbine. CAD model and animated working mechanism in PTC Creo.
  • Cradle to grave product analysis. Detailed material and lifecycle analysis of a rechargeable electric shaver.
  • Failure analysis of a machine shaft. Identified failure causes and proposed design solutions to reduce them.

04 · Experience

Research, engineering and sustainability.

Labs and organisations across France, Switzerland, the UK and Pakistan.

  1. May 2026 to Sep 2026

    Research Intern

    DRIVE-SIC Laboratory, ISAT, Université Bourgogne Europe · France

    PINN observer for a twelve state quadrotor under partial measurement. Hidden state RMSE ≈ 0.056, robust to noise and ±20% model error. First author paper in preparation.

  2. Jul 2025 to Nov 2025

    Environmental Data and Sustainability Intern

    Aga Khan Schools · Geneva, Switzerland

    Prototyped a microcontroller based solution for measuring carbon footprint. Structured water, energy and GHG metrics and coordinated with 10+ regional facility managers covering 100+ schools in 10 countries.

  3. Oct 2024 to Dec 2024

    Climate and Environment Intern

    Aga Khan University · London, UK

    Developed learning outcomes, shaped the conference theme and schedule, selected student presenters, identified guest speakers and managed logistics.

  4. Jul 2024 to Aug 2024

    Sustainable Buildings and Energy Audit Intern

    Aga Khan Agency for Habitat · Pakistan

    Energy monitoring and auditing, hazard vulnerability and risk assessment, early warning systems and hazard mapping, plus MEP site supervision.

  5. Sep 2022 to Mar 2024

    Research Assistant, 3D Modelling and Simulation

    NUST · Islamabad, Pakistan

    3D design and simulation in COMSOL, SolidWorks and Creo for chemical and material processes. Analysed porous media structures for catalyst supports and filters.

05 · Education and publications

Where I trained.

Sep 2024 to Sep 2026

Master's in Advanced Mechatronics

Université Savoie Mont Blanc · Polytech Annecy, France

Signals and systems, continuous control, modelling, simulation and numerical analysis, architecture and robotics.

15.34 / 20 · 120 ECTS

Sep 2018 to Aug 2022

Bachelor of Mechanical Engineering

University of Engineering and Technology · Peshawar, Pakistan

Manufacturing, mechatronics, production automation, automatic control, power plants, heat and mass transfer.

CGPA 3.36 / 4 · 240 ECTS

Journal paper · in preparation

Learning to observe: physics-informed neural network design for UAV state estimation under model uncertainty

S. A. Baig, A. Chaibet

Extends PINN-Obs to a twelve state, controller driven quadrotor, with open source code and datasets.

Repository

06 · Skills

Tools I use every week.

Control and estimation

Nonlinear observers, PINNs, dynamic modelling, state estimation, MATLAB/Simulink, Simscape

Robotics

ROS 2 Humble, ROS 1 Noetic, Navigation2, SLAM, Gazebo, RViz, Docker, Git

Embedded and IoT

STM32, ESP32, Raspberry Pi, Arduino, UART/SPI/I2C, IMU, Lidar, camera, motor drivers

Programming and AI

Python, PyTorch, C++, Flask, Model Context Protocol (MCP) servers

CAD and simulation

SolidWorks, PTC Creo, AutoCAD, COMSOL Multiphysics, FEA

Energy systems

Thermodynamics, heat transfer, energy auditing, carbon and GHG accounting

07 · Contact

Let's work on autonomous systems together.

I am available at one week's notice and open to relocating anywhere in France or Europe. The best way to reach me is by email.